Robotic Manipulator Kinematics, Dynamics, and Control System Design
This case study investigated the kinematic, dynamic, and control aspects of a multi-joint robotic manipulator. The analysis demonstrated a comprehensive methodology for system modeling, structural sizing, and controller implementation to achieve desired motion profiles.
Project Overview
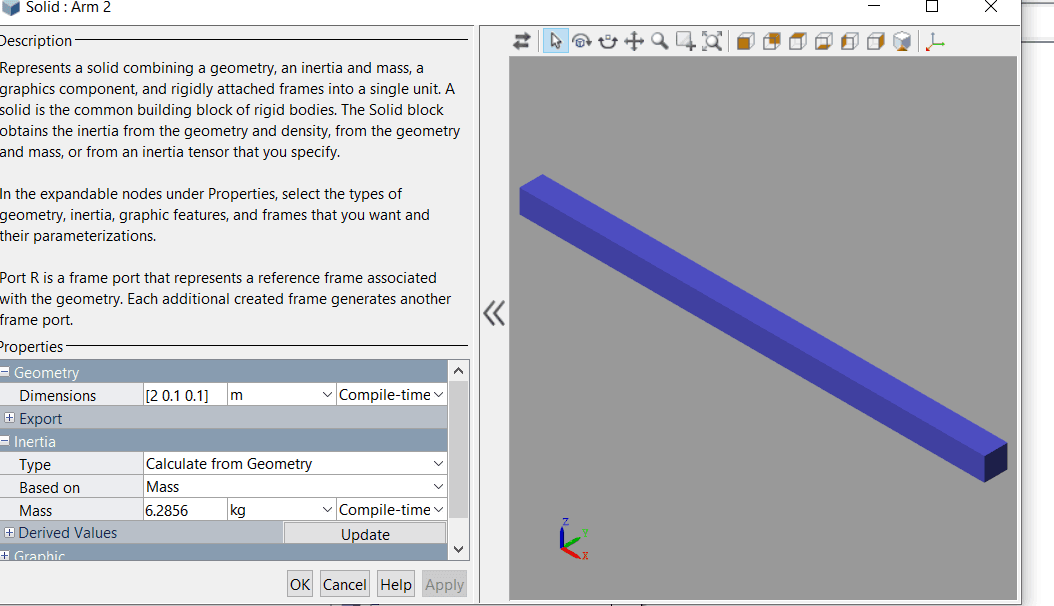
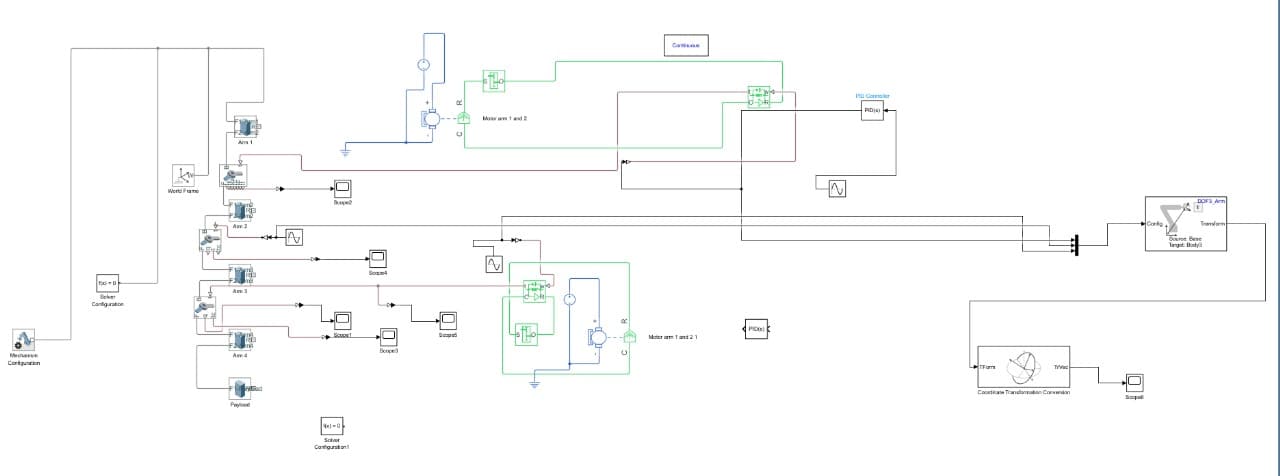
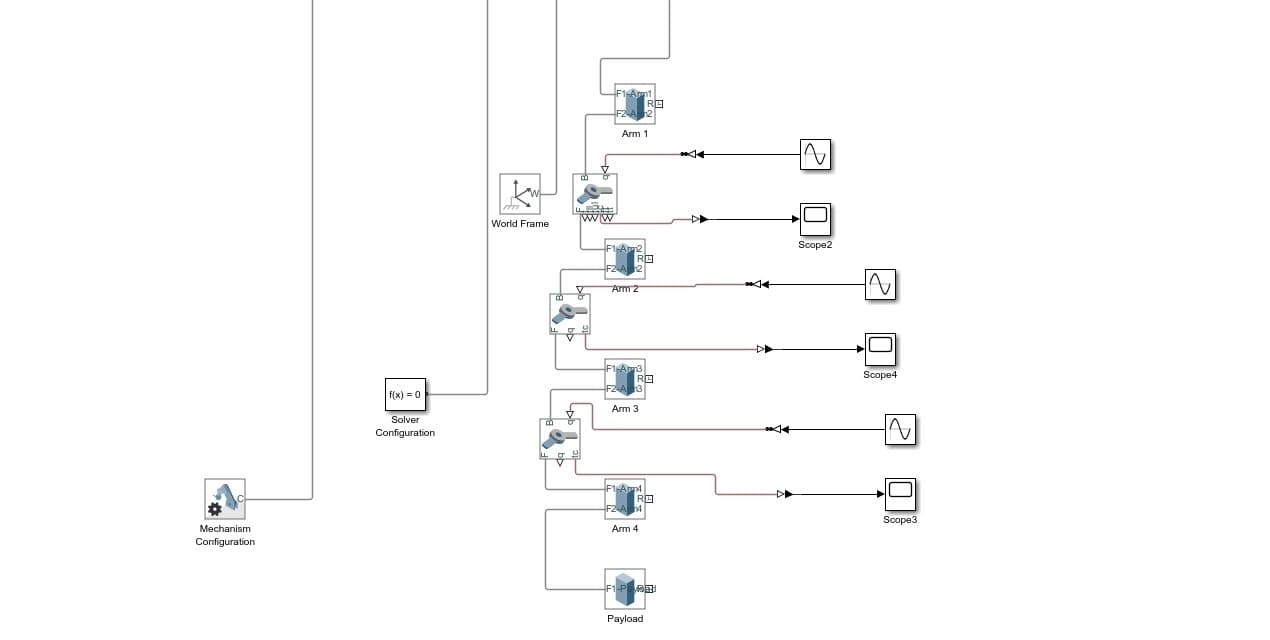
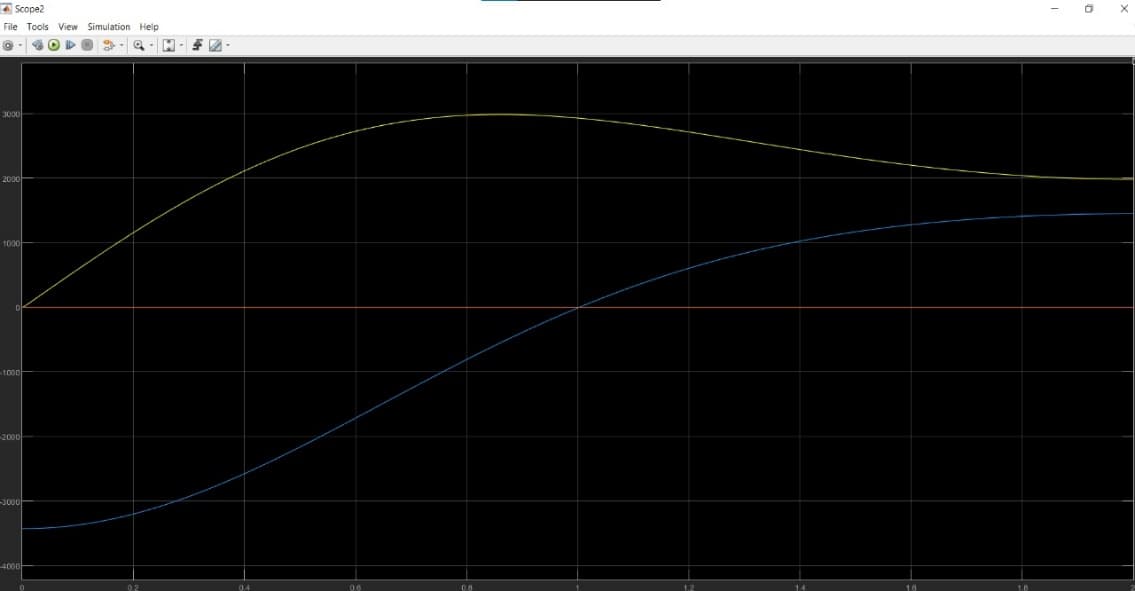
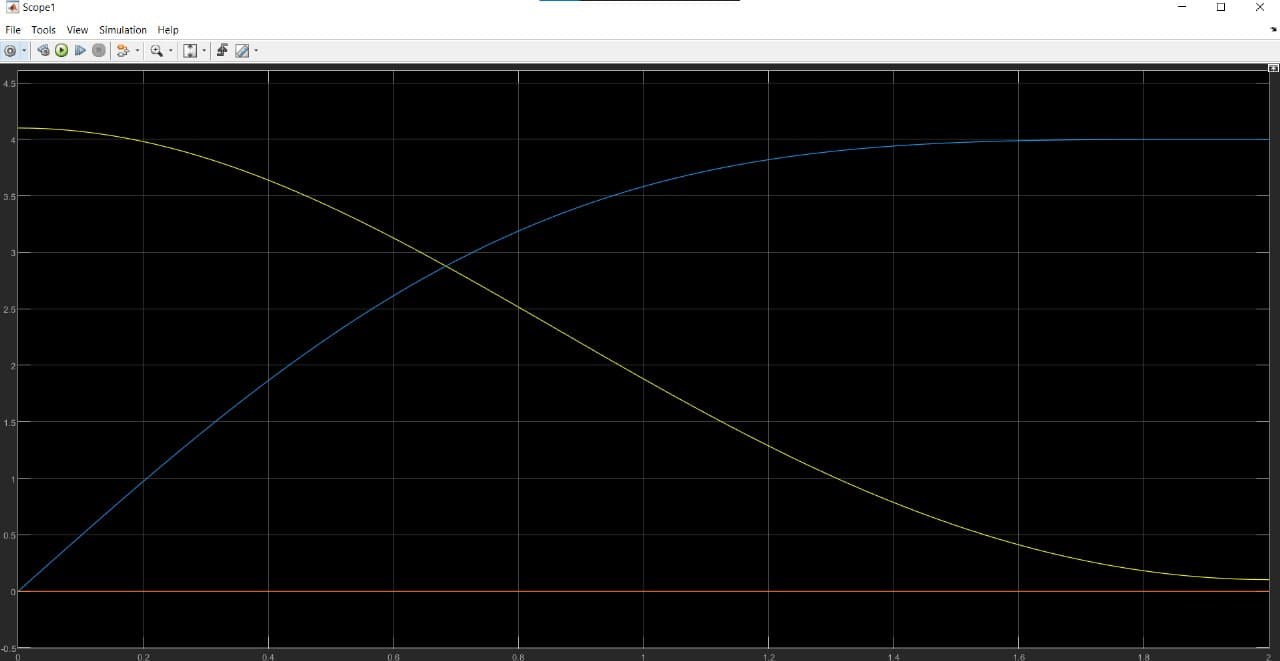
This project involved a comprehensive engineering analysis of a multi-joint robotic arm, starting with the derivation of Denavit-Hartenberg parameters to establish its kinematic model. Structural integrity was assessed through calculations of bending moments, stresses, and deflections under a representative payload, informing the selection of appropriate cross-sectional dimensions and material properties. A detailed multibody dynamics model was constructed in MATLAB Simulink, incorporating rigid body segments, revolute joints, and gravitational effects. The model was then used to simulate various motion profiles, enabling the measurement of required joint torques. Subsequently, suitable motor and gearbox combinations were selected, and PID controllers were designed and tuned to ensure precise trajectory tracking and minimize positional errors, validating the integrated design approach.
Results
Need a similar simulation?
Get a fixed-price quote within 24 hours.